Insights
Industry insights on robot applications, automation and selection — field notes from the Yigaite engineering team.

Specifying a Six-Axis Robot Cell for Insert Extraction and Unscrewing/De-Molding: A Sourcing FAQ
A practical sourcing guide for manufacturing engineers and procurement teams evaluating six-axis robot cells for insert extraction, unscrewing, and de-molding — covering torque-reactive end-of-arm tooling, thread engagement, part ejection and drop detection, cycle-time matching, and insert reuse handling.
What Does a Robot Workcell Include? A Buyer's FAQ Guide (vs. a Standalone Robot)
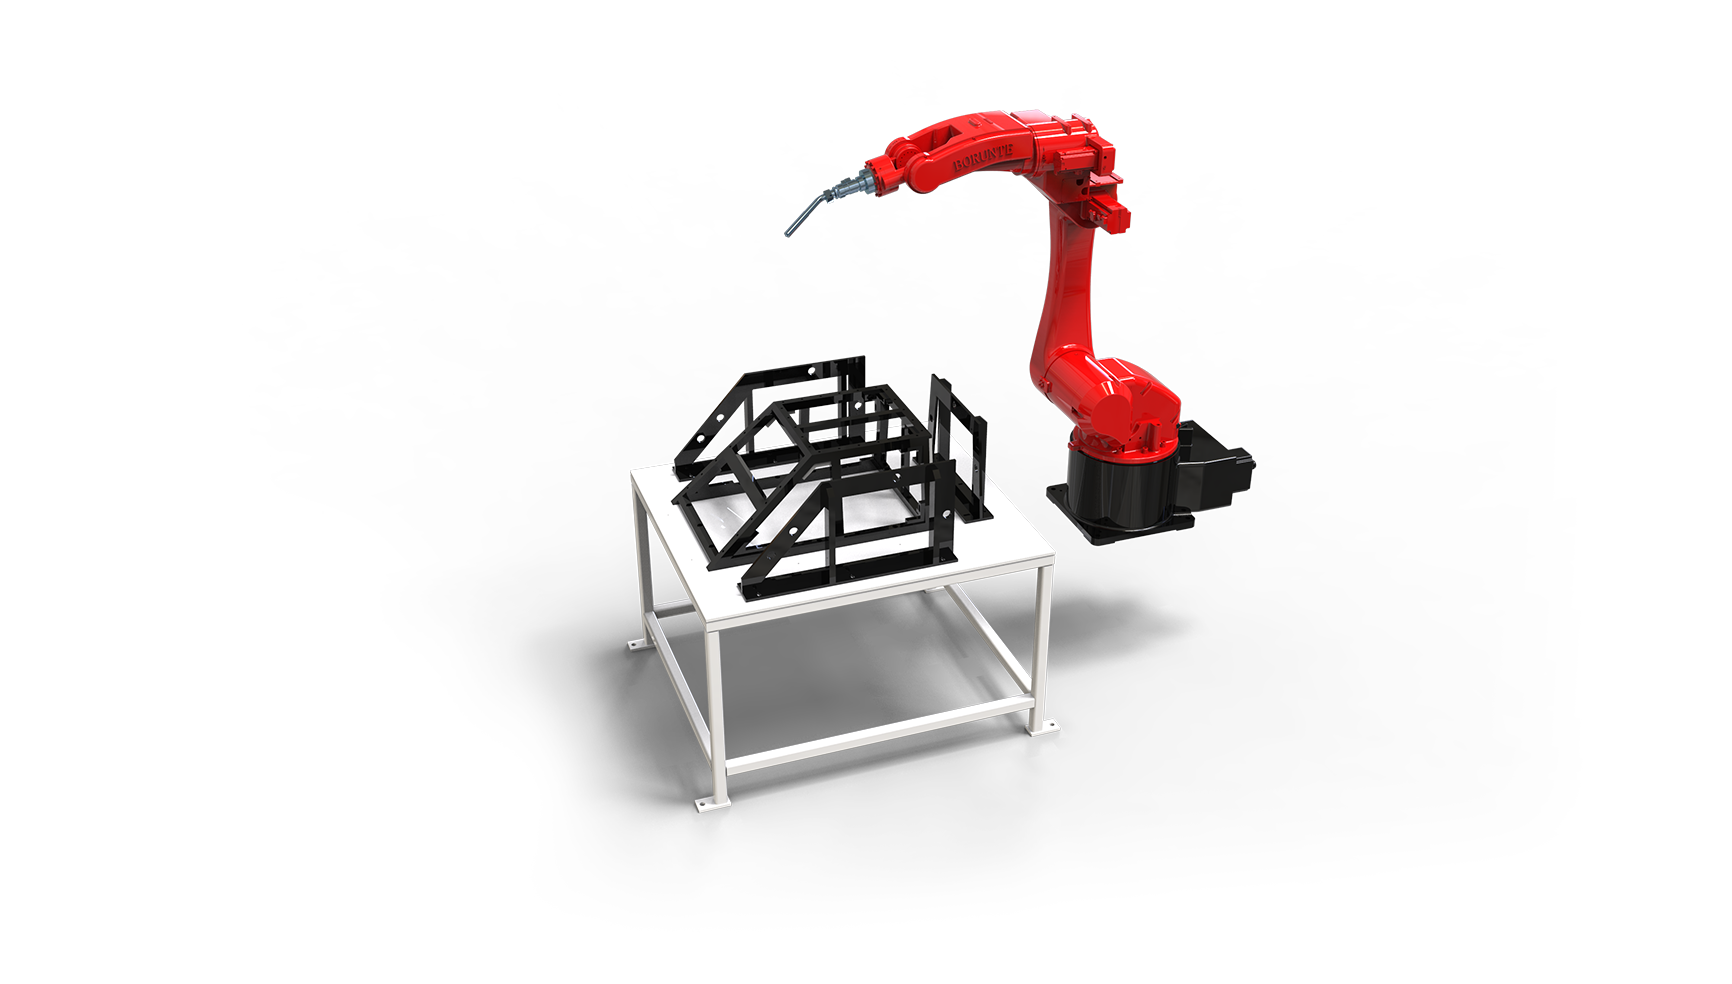
A standalone robot is one component. A working welding cell also needs guarding, a positioner, end-of-arm tooling, controls, safety systems and commissioning — this FAQ guide explains each layer, using the YGT dual-axis welding positioner and BRTIRWD1506A welding cell as a worked example.
Buyer's FAQ: Integrating YGT Welding Positioners with a BRTIRWD1506A Robot Welding Cell
A practical buyer's guide to integrating single-axis and double-axis welding positioners with a BRTIRWD1506A six-axis robot welding cell — covering load/unload side, rotation timing, grounding, fixture changeover, and the safety envelope.

Specifying a BRTIRUS0805A Six-Axis Robot Cell for Semiconductor Chip Loading and Unloading: A Sourcing FAQ
A sourcing-oriented guide for back-end and test-house engineers evaluating a BRTIRUS0805A-based chip handling cell — covering placement repeatability, ESD-safe end-of-arm tooling, tray and magazine handling, cleanroom compatibility, and cycle-time matching.

Robot Spray Painting Cells with Two-Station Rotary Turntables: A Sourcing FAQ for High-Mix Cosmetic Parts
A practical sourcing FAQ for engineers specifying two-station rotary turntable robot spray painting cells — covering turntable indexing, gun triggering, part-present sensing, overspray and booth airflow exposure, and cycle matching for high-mix cosmetic parts.

Specifying Robot Cells for CNC Lathe Bar Feeding and Long-Shaft Part Transfer: A Buyer's FAQ
A buyer-facing engineering guide to specifying robot cells for CNC lathe bar feeding and long-shaft part transfer — covering gripper and tailstock clearance, reach and payload for shaft overhang, cycle synchronization with bar feeders, and how to choose between one-to-one and one-to-two layouts.

Die Casting Extraction Cell Sourcing FAQ: Track-Mounted Six-Axis Robot in a One-to-Two Layout
A practical sourcing guide for engineers specifying a single track-mounted six-axis robot to extract castings from two die casting machines — covering machine spacing, rail length, gripper reach into the die, cycle interleaving, and how this cell differs from the wheel-loading and bar-feeding cell.
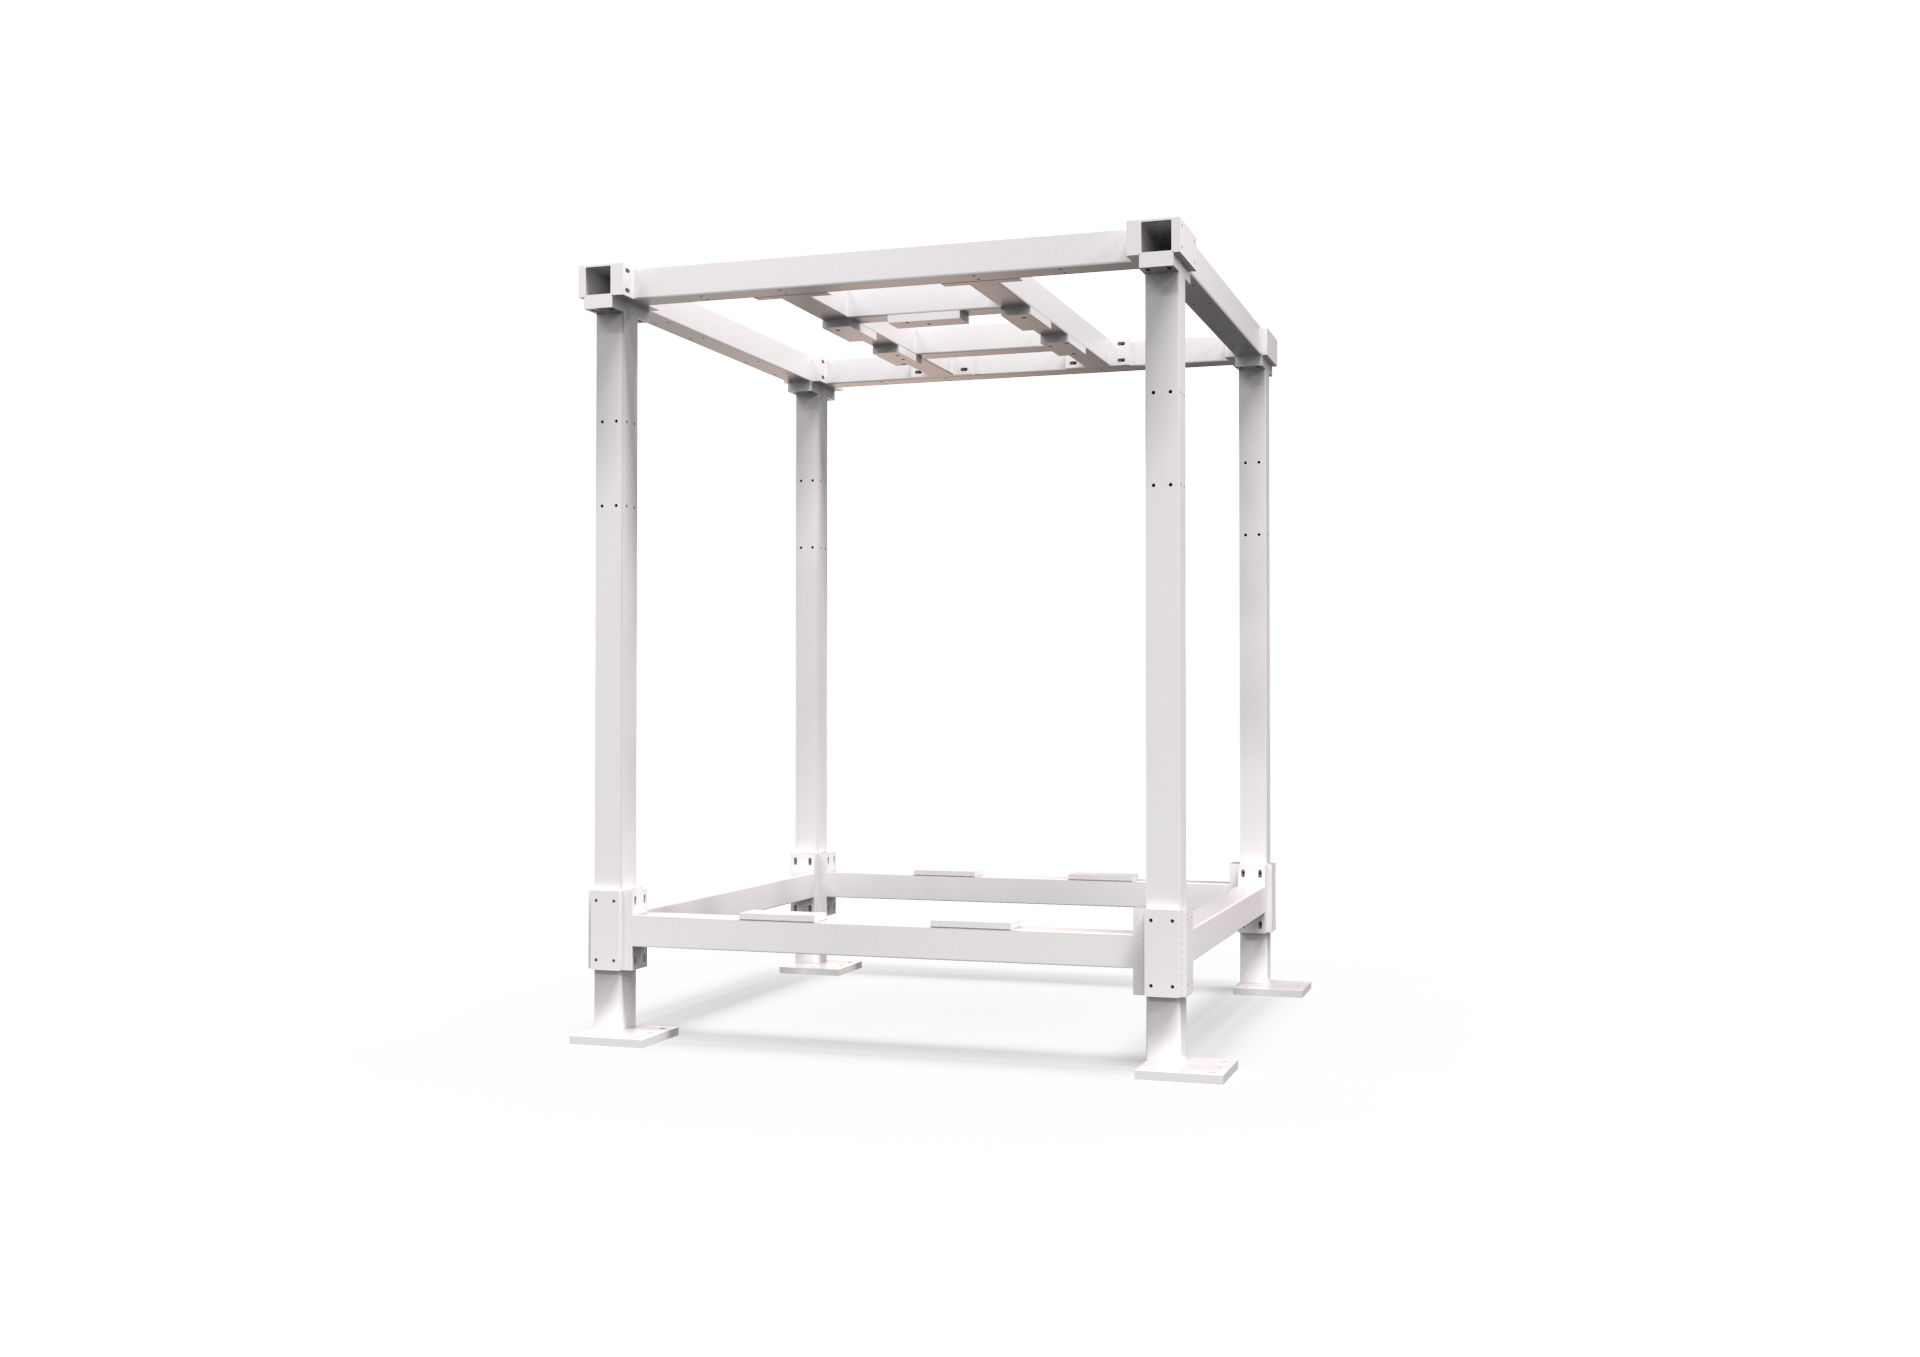
Parallel Robot Mounting Frame & Structural Integration: FAQ for High-Speed Pick-and-Place Cells
Practical answers on frame stiffness, vibration behaviour, vision alignment, and structural integration when building a high-speed pick-and-place cell around a parallel robot — written for automation engineers and project managers who have to specify the frame, not just the robot.
BRTIRUS1820A Sourcing Guide for Heavy-Part Handling Cells: Wheel Loading, Die Casting Extraction, and Bar Feeding
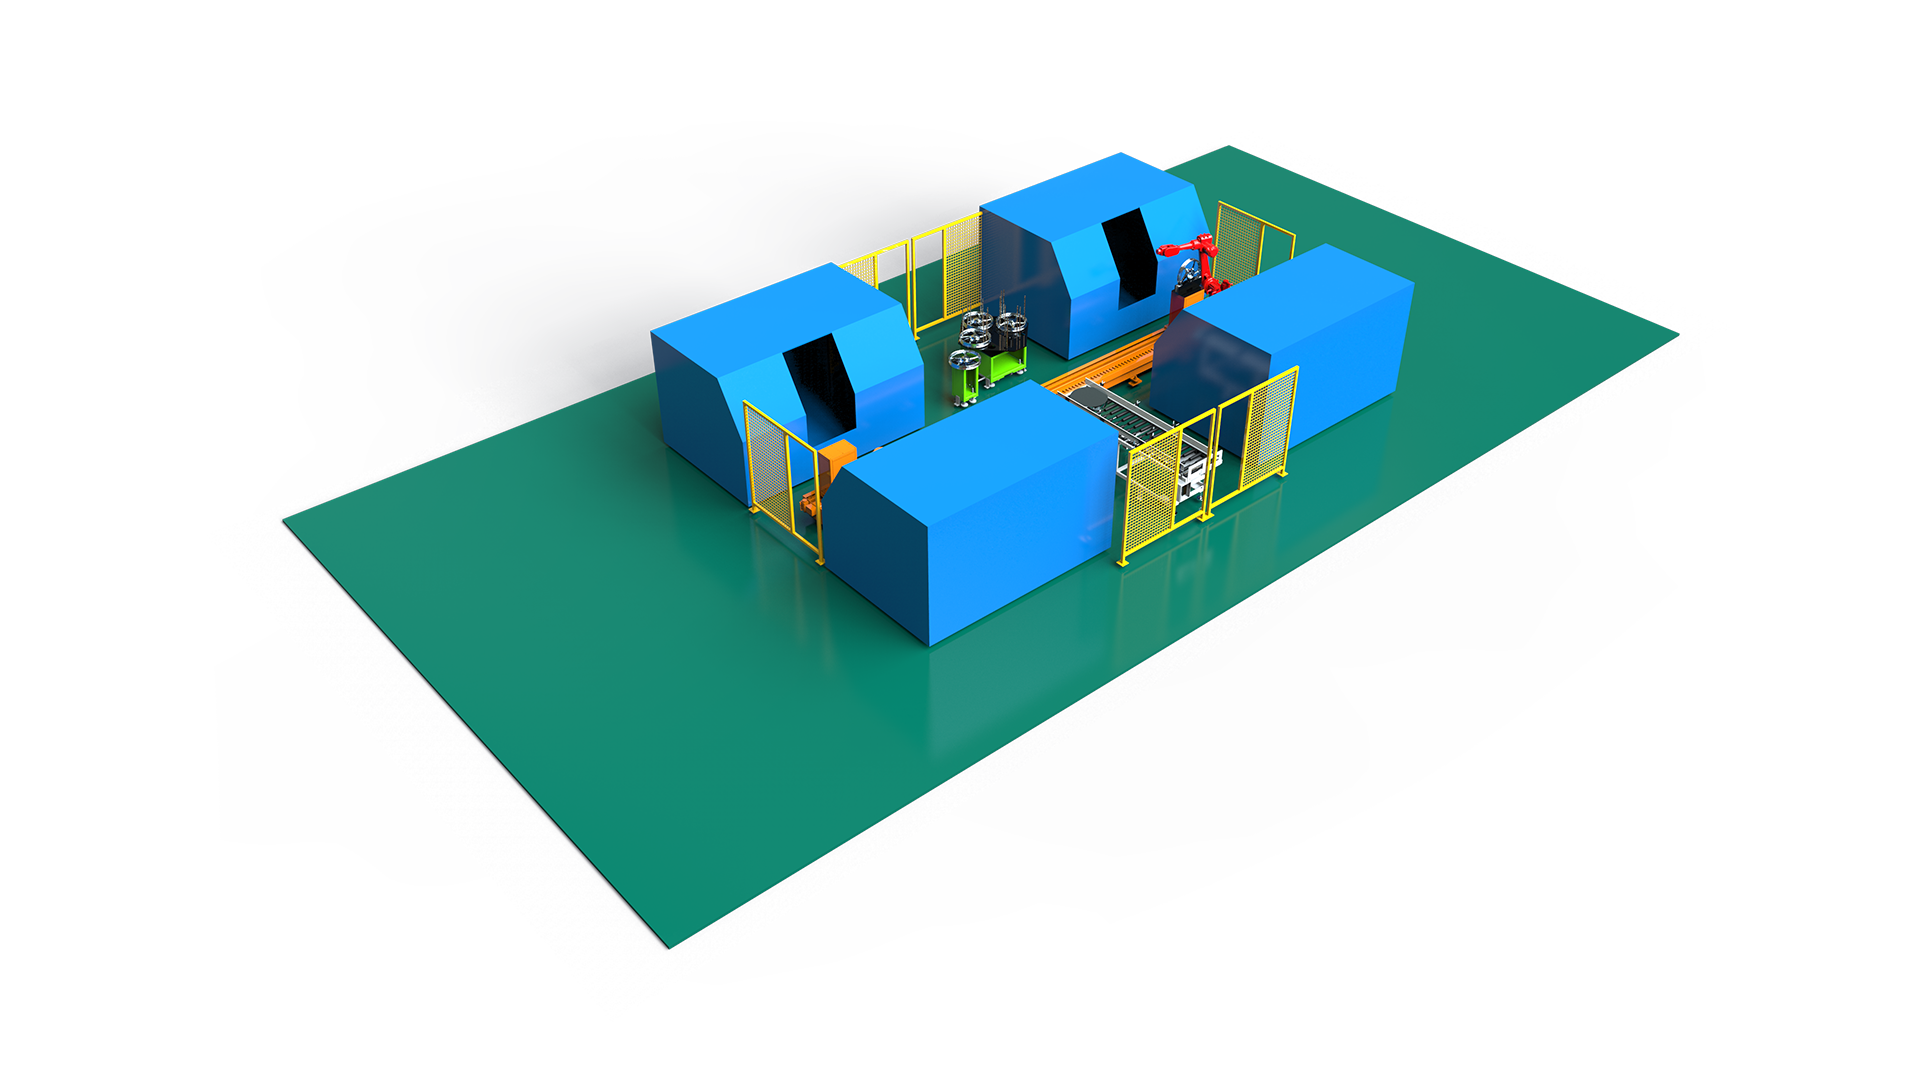
A practical selection guide for process engineers evaluating the BRTIRUS1820A six-axis robot in one-to-four wheel loading cells, gantry-track one-to-two die casting extraction, and bar feeding tables — covering payload, reach, gripper choice, and cell layout.
Robot Cell Electrical & Control Cabinet Integration for CNC Machine Tending: Layout, Cabling and Signal Handshaking
A practical engineering guide to the electrical and control side of machine tending robot cells — how to plan floor space around the robot base cabinet, route power and signal cabling without creating maintenance traps, and establish reliable machine-to-robot handshaking — with reference to BRTIRUS1510A and BRTIRUS1820A cell configurations.

Sourcing FAQ: Specifying a Robot Cell for Tapping Machine and Secondary Threading Operations — Part Transfer, Spindle Orientation, Chip/Coolant Exposure, Torque-Reactive Fixturing, and Cycle Matching with BRTIRUS1820A
A sourcing-oriented FAQ for engineers specifying a robot cell around a tapping machine: how to think about part transfer, spindle orientation, chip and coolant exposure, torque-reactive fixturing, and cycle matching — with BRTIRUS1820A as the reference robot platform.

Sourcing FAQ: Specifying Six-Axis Robot Cells for High-Cavitation Injection Molding — Sprue Picking, Insert Loading and Take-Out Boxing
A practical sourcing guide for injection molders evaluating six-axis robot cells for high-cavitation tooling — covering gripper and end-of-arm tooling selection, cycle-time matching, sprue picking, insert loading, take-out boxing, and how a platform such as the BRTIRUS1510A is specified and integrated into a working cell.
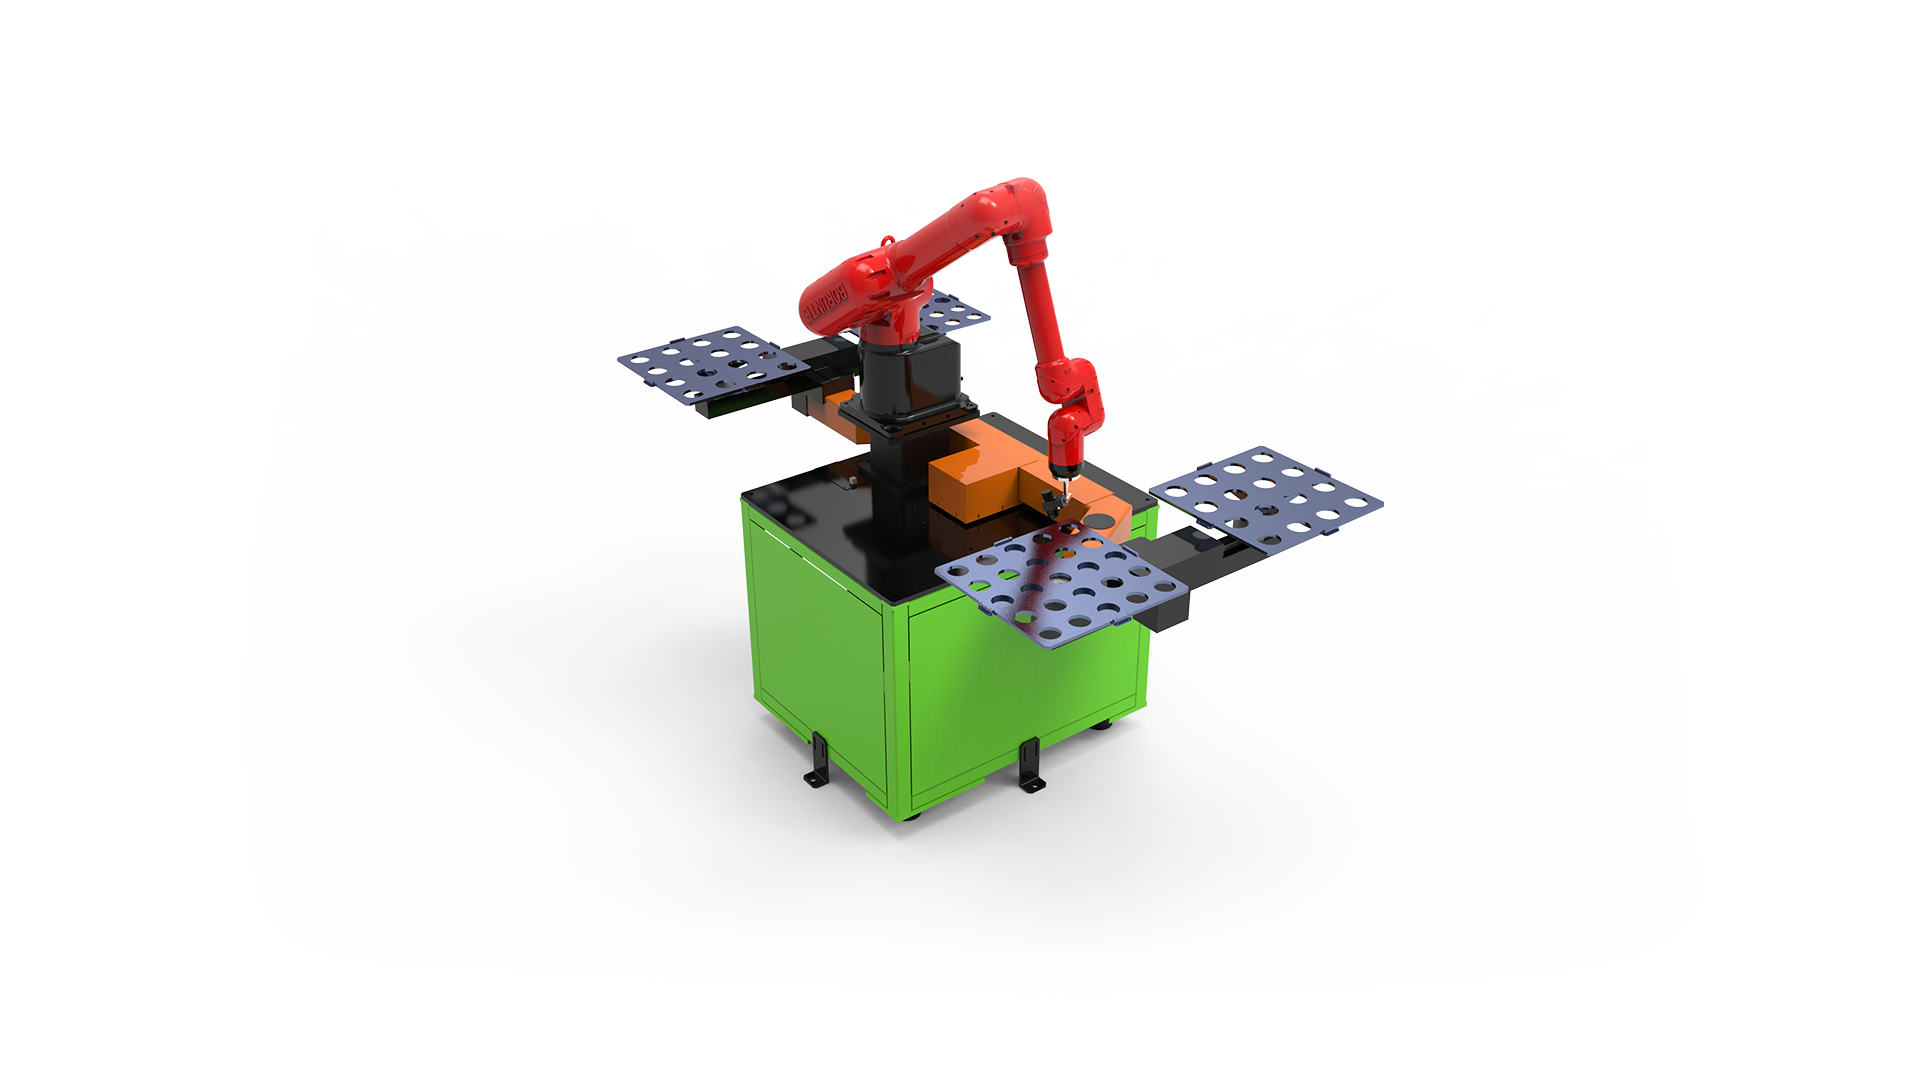
Buyer's FAQ: Specifying Robot Spray Painting Cells with Turntables and Multi-Station Layouts
A practical buying guide for engineers and procurement teams planning robot spray painting cells — covering cycle time logic, part fixturing, booth integration, and how four-station and two-station turntable layouts change the specification conversation.
How to Select a Robot Cell for Post-Machining Secondary Operations: Deburring, Edge Grinding and Polishing
A sourcing guide for manufacturing engineers evaluating robotic deburring, edge grinding and polishing cells after CNC machining — how to match robot payload and reach to part geometry, specify compliant force control and abrasive tooling, and justify the investment when the CNC cycle is already running.
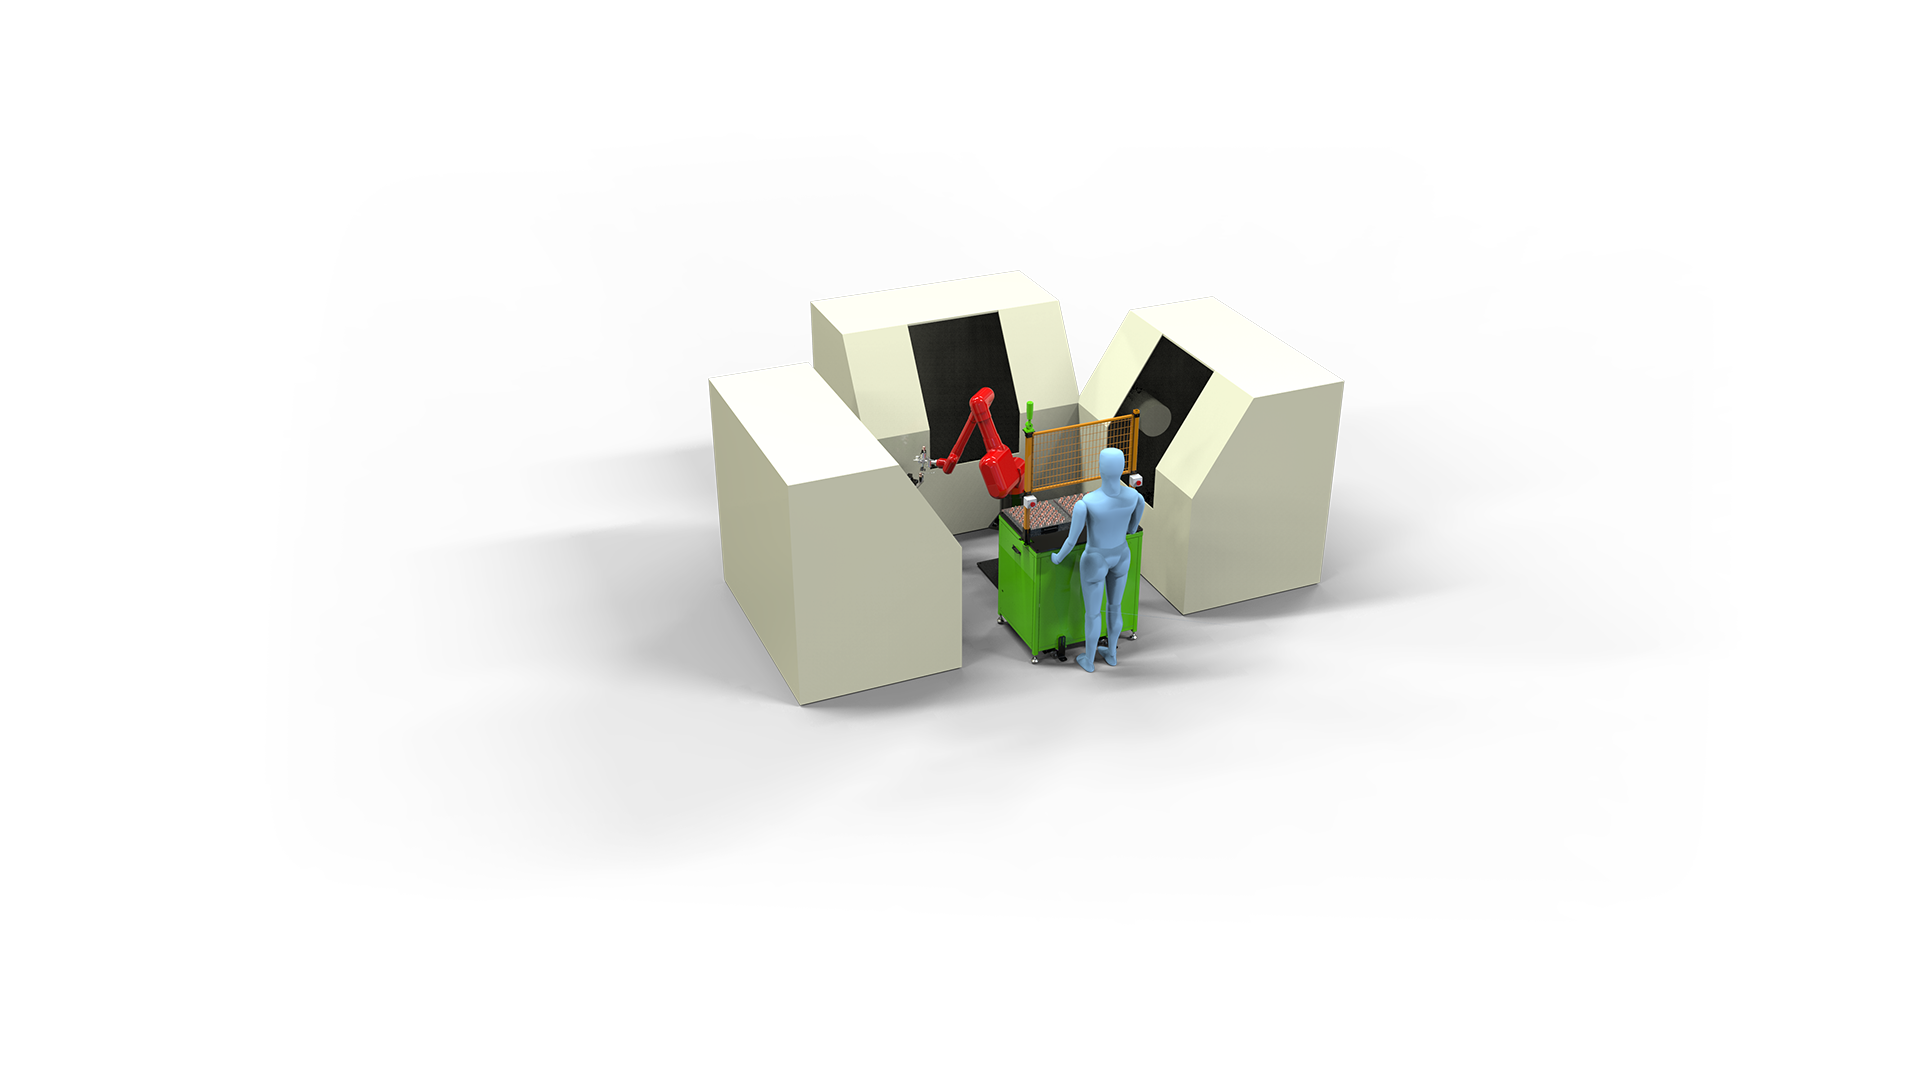
Six-Axis Robot Tending for CNC Lathes: A Selection Guide for One-to-Many Layouts, Bar Feeding, and Payload/Reach/Cycle Matching
A practical selection guide for integrating six-axis robot tending units into existing CNC turning cells — covering one-to-many layout logic, bar and billet feeding requirements, and how to match payload, reach, and cycle time between the BRTIRUS1510A and BRTIRUS1820A.
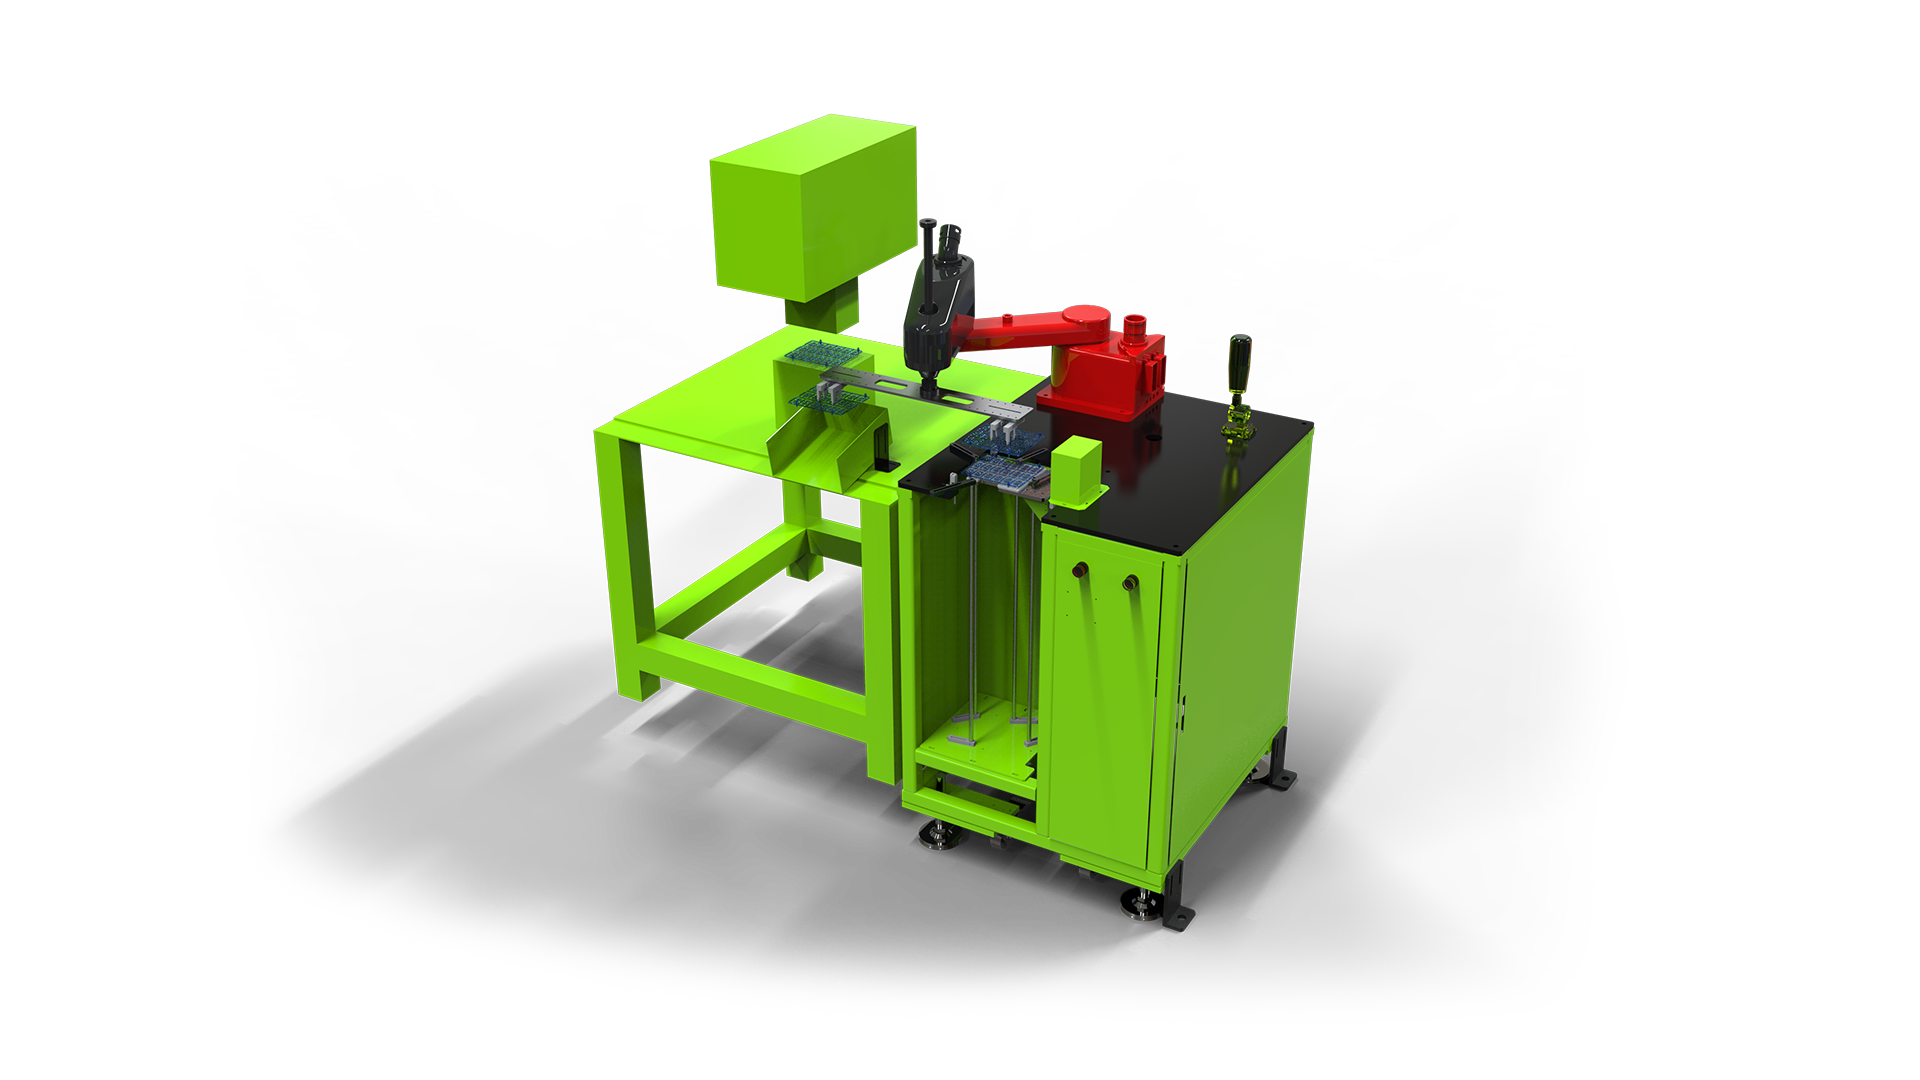
Sourcing a BRTIRSC0603A Four-Axis Robot for Small-Part Pick-and-Place and Machine Loading
A practical sourcing guide for engineers evaluating the BRTIRSC0603A compact four-axis robot in small-part pick-and-place and machine-tending cells — covering reach and payload checks, cycle-time fit, gripper and fixture interfaces, and the integration questions worth answering before you commit.
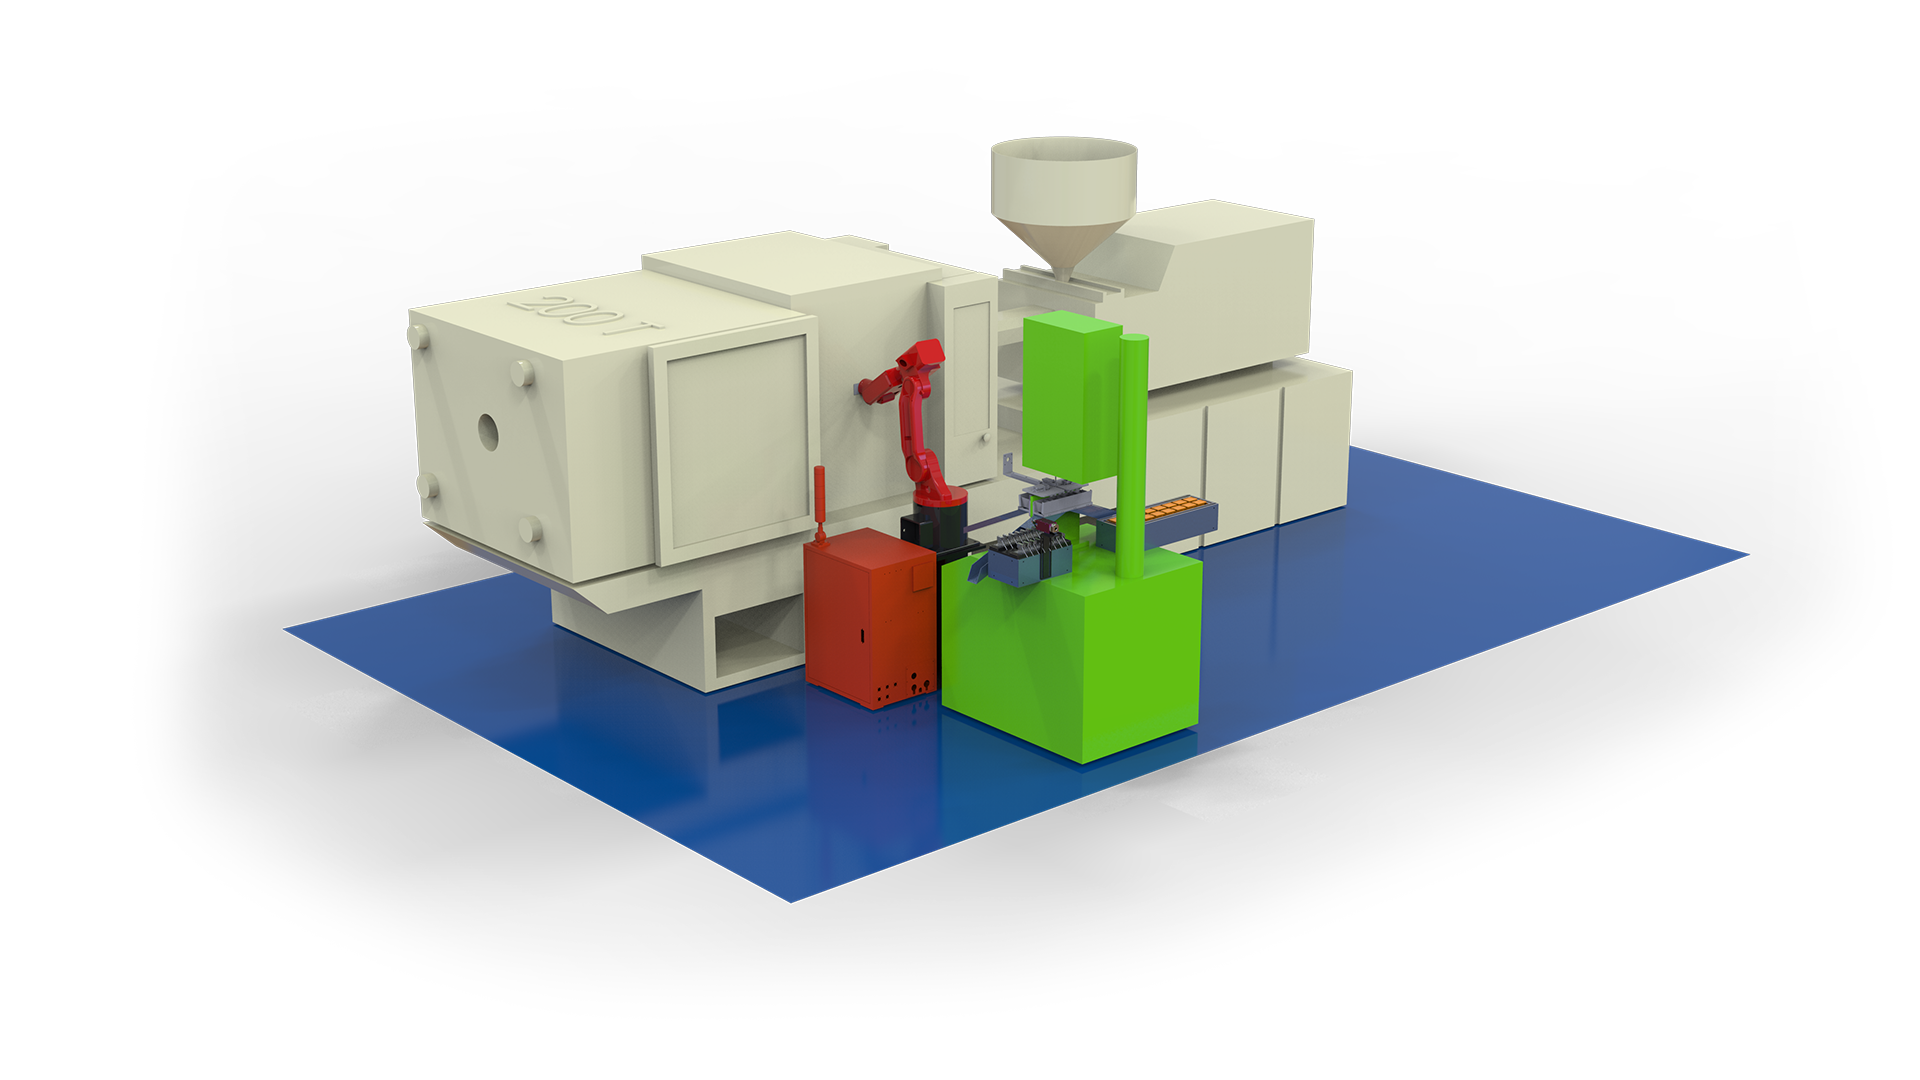
Ultrasonic Sprue Cutting, Counting & Cavity Sorting Cells with BRTIRUS0805A: A Sourcing Guide for Injection Molding Buyers
A practical sourcing guide for injection molding teams evaluating robotic ultrasonic degating cells — covering cycle-time targets, degating quality checks, cavity-level counting and sorting, acceptance criteria, and how to specify a cell around a 5 kg / 990 mm reach six-axis platform such as the BRTIRUS0805A.

Specifying Robot End-of-Arm Tooling and Gripper Interfaces for Insert Molding, Nut Embedding, and Sprue Picking Cells
A practical specification guide for injection molding engineers and automation integrators selecting end-of-arm tooling (EOAT) and gripper interfaces for insert molding, nut embedding, and sprue picking cells — covering payload budgeting, vacuum vs. mechanical gripping, interface standards, part-present verification, and mold-area integration logic.
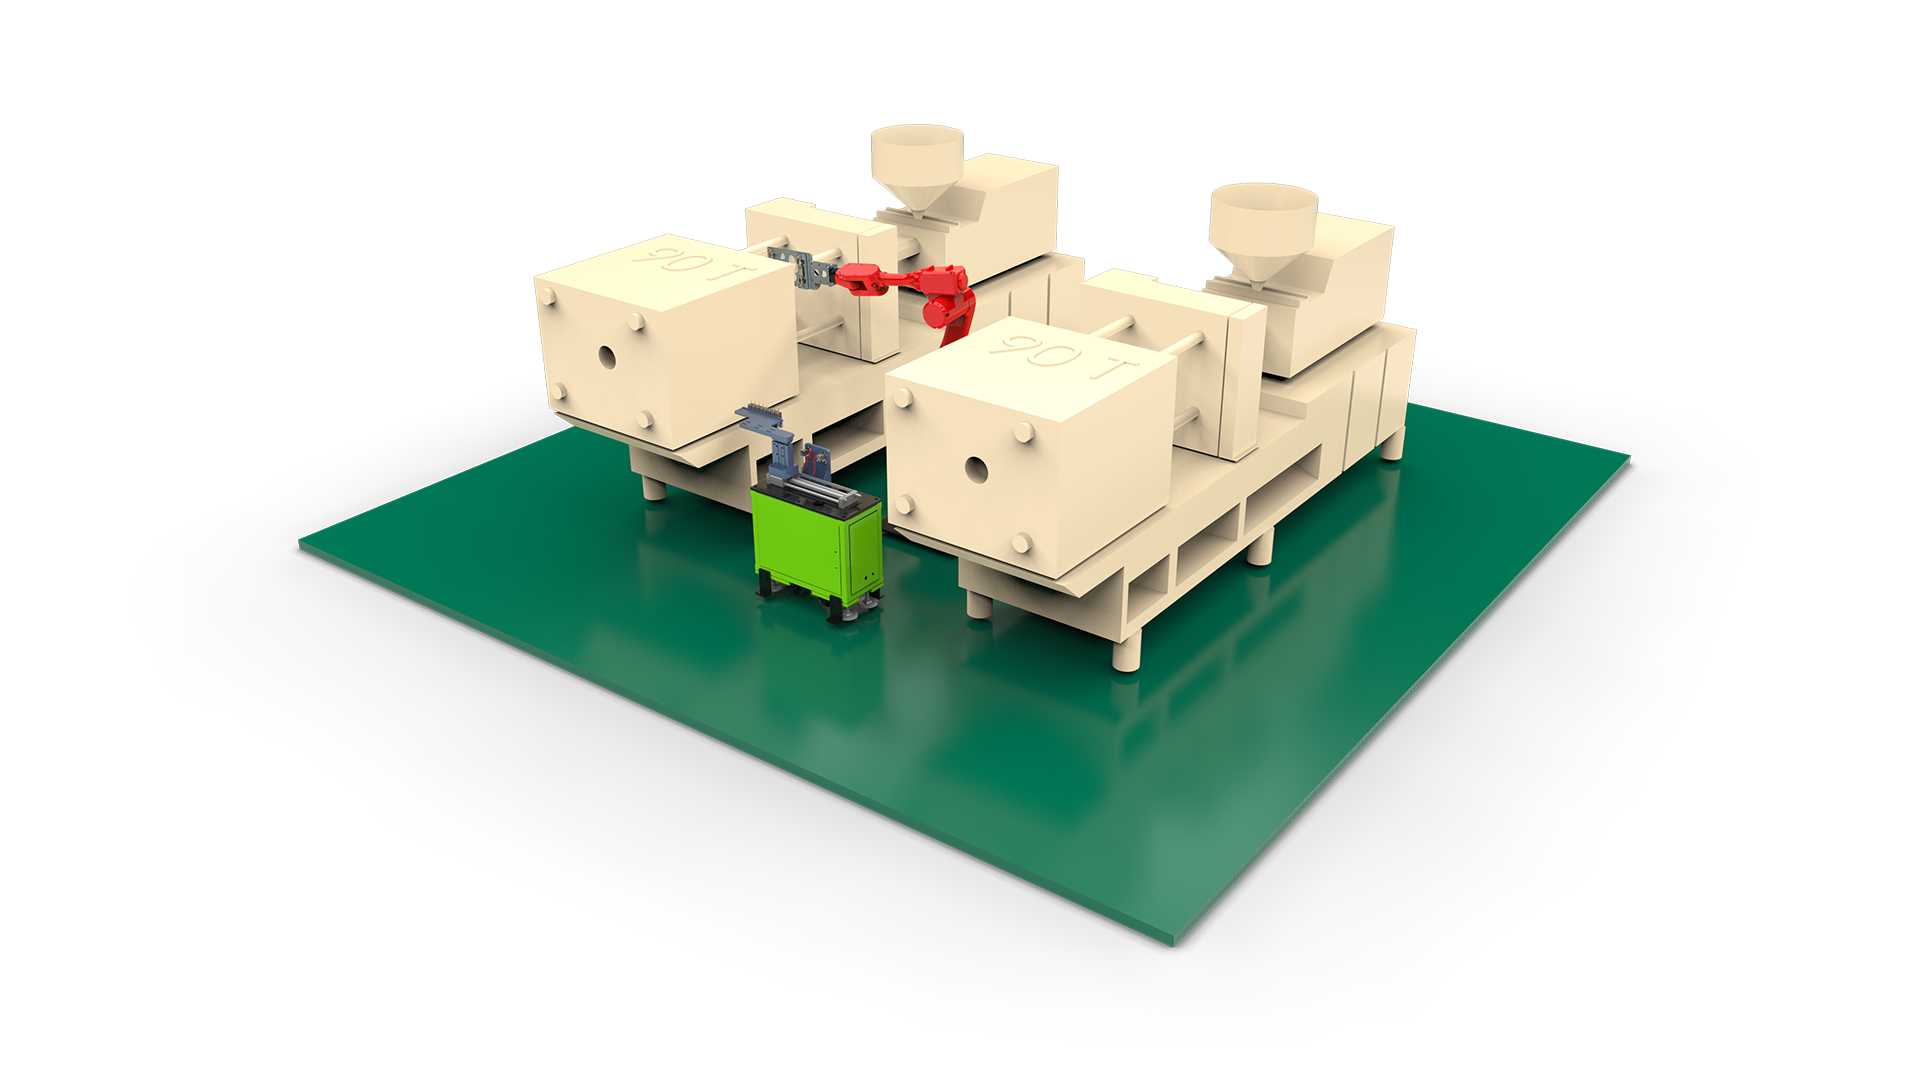
How to Specify a Robot Cell for Glue Insertion and Insert Molding: An FAQ Guide for Injection Molding Engineers
A practical specification guide for engineers planning glue insertion and insert molding cells — covering payload and reach calculations, mold interface and cycle-time logic, part-presentation and insertion accuracy, plus a reference configuration using the BRTIRUS1510A in an eight-cavity toothbrush overmolding cell.

Robot CNC Machine Tending for High-Mix Low-Volume Shops: 4-Axis vs 6-Axis, One-to-One vs One-to-Three
A practical buying guide for high-mix low-volume machine shops evaluating robot CNC tending — covering one-robot-to-three-machine layouts, bar stock feeding, and how to choose between a 4-axis model like the BRTIRPZ1508A and a 6-axis model like the BRTIRUS1510A.
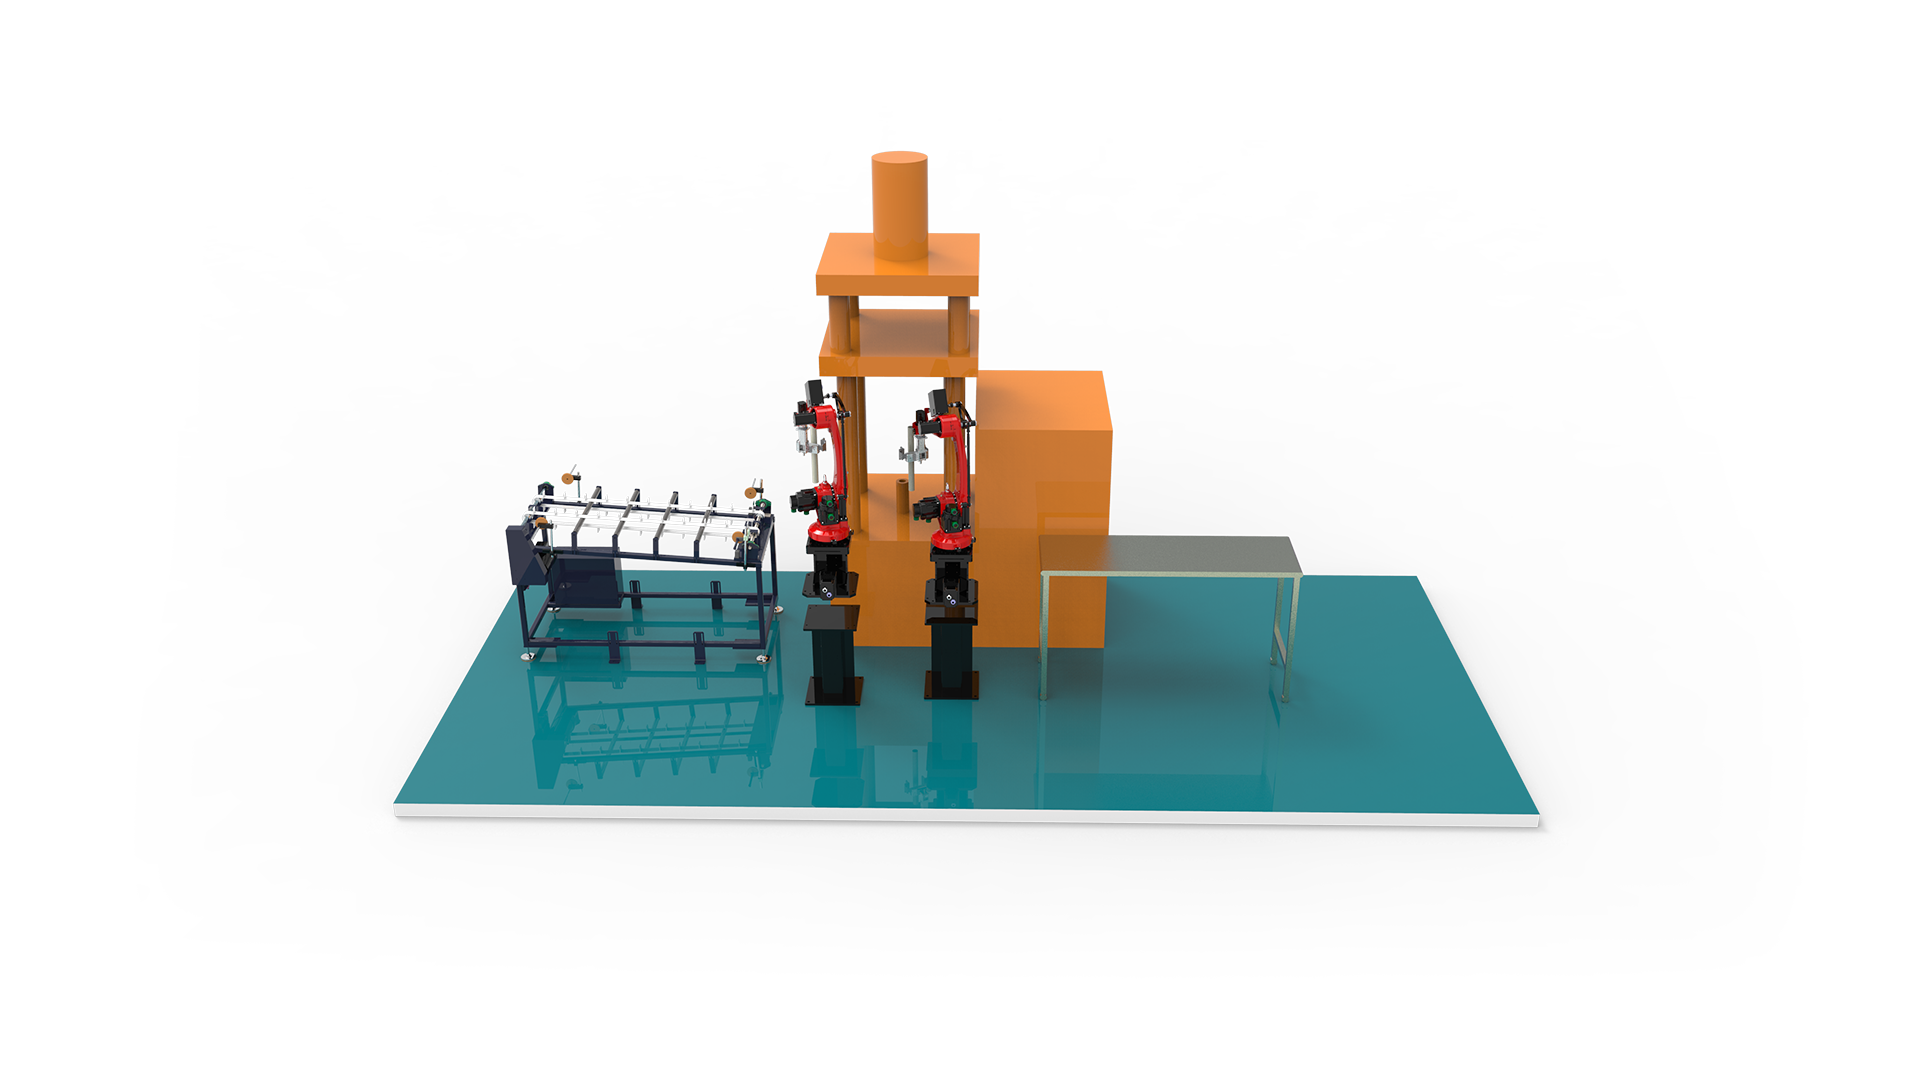
4-Axis vs. 6-Axis Robots for Press Brake Tending: How to Choose the Right Automation
Choosing between a 4-axis and a 6-axis robot for press brake tending depends on your parts, die setup, and workflow complexity. This guide compares the two architectures—using the BRTIRPZ1508A and BRTIRUS1820A as benchmarks—to help you match the right robot to your bending application.
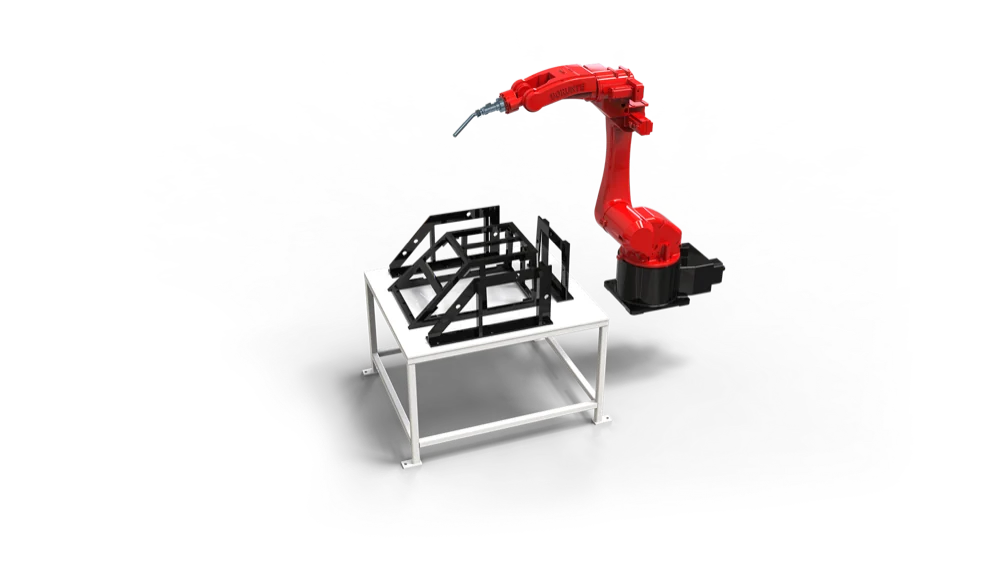
Robot Welding Automation: A Practical Guide
How to automate arc and spot welding with 6-axis robots — cell layout, positioners, seam tracking, cycle time and a realistic ROI view.
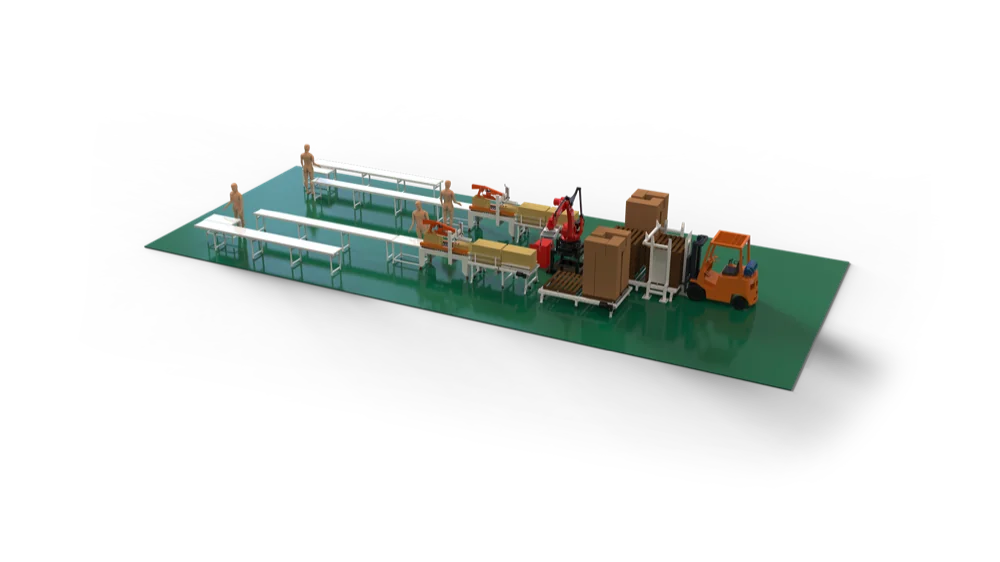
Robot Palletizing: Stack More, Lift Less
Automating end-of-line palletizing with robots — payload and gripper choice, cases per minute, pallet patterns and a realistic payback view.
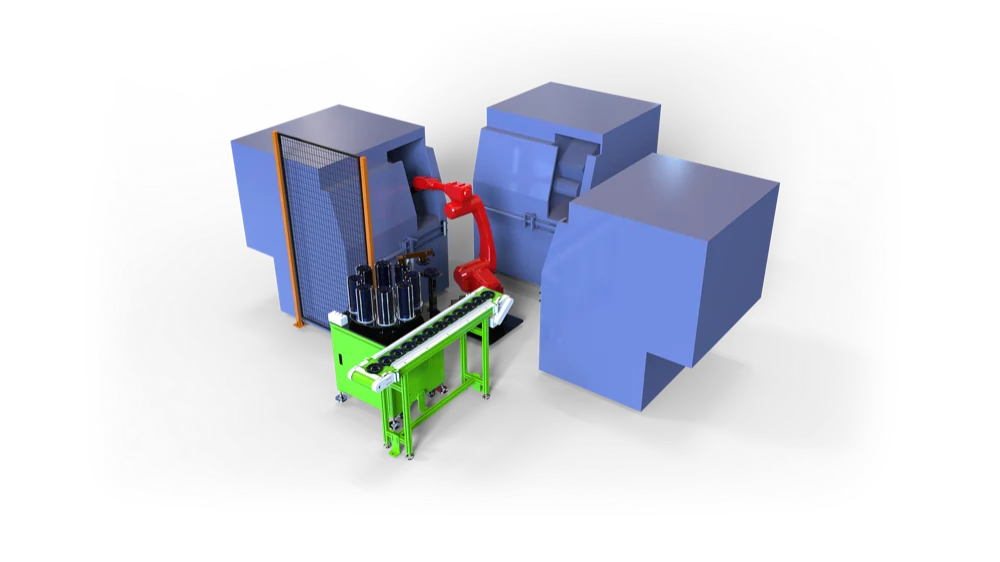
Robot Machine Tending: Keep the Spindle Running
How robot machine tending raises CNC spindle uptime — reach, payload, dual grippers, part presentation and lights-out shifts.